Registered Address: 32D Floor Guomao Building, No.388, Hubin South Road, Siming District, Xiamen,Fujian, China
ISO 9001:2015 Certified
Our quality management system covers sourcing,testing and dispatch
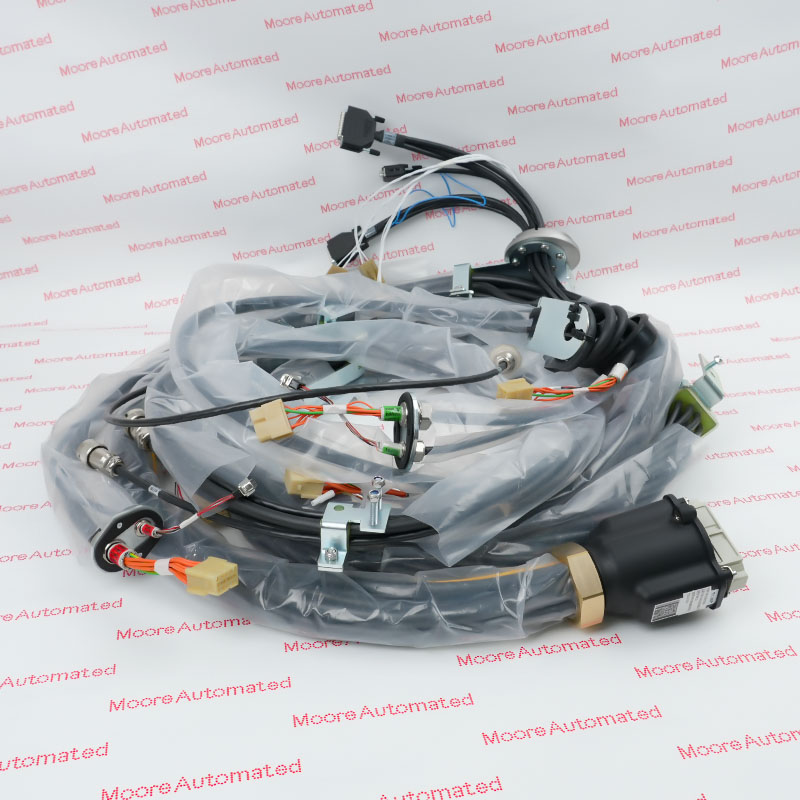


ABB article 3HAC033388-001 identifies a robot cable harness associated with axes 1–6. Selection is controlled by the complete robot type, serial number, manipulator revision and installed dress/cabling execution. Use it only in the robot configuration whose ABB spare-parts list names 3HAC033388-001. Confirm article number, IRB 6600 variant, robot serial number, axis routing, controller connection, connector keying, cable length and any dress-pack options.
3HAC033388-001 is selected from the complete manufacturer identity and receiving-system evidence. Power down and lock out the robot, record routing/clamps and connector positions, support the arm and follow the ABB manipulator service procedure. Check insulation and continuity, then jog each axis at reduced speed while observing clearance, strain relief, bend radius and controller diagnostics.
Verify the full IRB 6600 type, serial number and parts list before selecting the harness.
Reproduce every clamp, service loop, protective sleeve and bend radius through axes 1–6.
Jog the robot through the approved envelope while checking clearance, tension and cable diagnostics.
An axes 1–6 harness is repeatedly flexed by the manipulator. Clamp positions, service-loop length, twist orientation and bend radius must reproduce the ABB routing so motion does not pull connectors or abrade the jacket.
Harness work requires robot isolation and controlled support of moving links. After replacement, verify connector interlocks and safety circuits, then use reduced-speed axis motion to confirm routing before returning to programmed production.
Availability and lifecycle status are confirmed for the exact 3HAC033388-001 article at quotation.
Moore Automated verifies the supplied condition, included items and installed-system match against the complete manufacturer identity.
The replacement must be commissioned with the checks listed in the technical sections.
Registered Address: 32D Floor Guomao Building, No.388, Hubin South Road, Siming District, Xiamen,Fujian, China
MooreAutomated.com is the official website and primary online platform operated by Moore Automation Limited. The website provides information about the company’s industrial automation parts sourcing services, product coverage and customer support. Moore Automation Limited operates as an independent supplier and is not an authorized distributor or representative of the manufacturers displayed on this website unless expressly stated.